
Browse
odometry
-
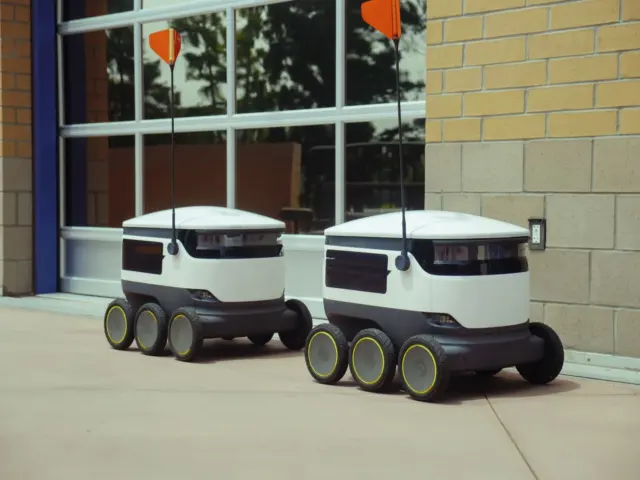
How Indoor Robots Localize Without GPS
Position source What it gives the robot Main weakness Planning use Wheel odometry Change in position relative to the previous…
Browse
Position source What it gives the robot Main weakness Planning use Wheel odometry Change in position relative to the previous…