Browse
Indoor Autonomous Robots
-
Model Predictive Path Integral Control for Robots
Effect of using MPPI What is supported Planning use Freedom in the cost function Non-quadratic and even discontinuous cost forms…
-
Obstacle Avoidance for Indoor Robots
Quick answer: how do autonomous robots avoid obstacles? They sense them, record them on a costmap, and let a local…
-
Occupancy Grid Maps Explained
A robot at a doorway needs to know what is blocked. So what is an occupancy grid map? A grid…
-
How Robots Build Maps of Indoor Spaces
Phase What happens Planning use Explore The robot moves through the space while a range sensor such as lidar streams…
-
Lidar vs Camera Navigation for Indoor Robots
For lidar vs camera for robot navigation indoors, choose lidar when reliable distance measurement matters most, a camera when cost…
-
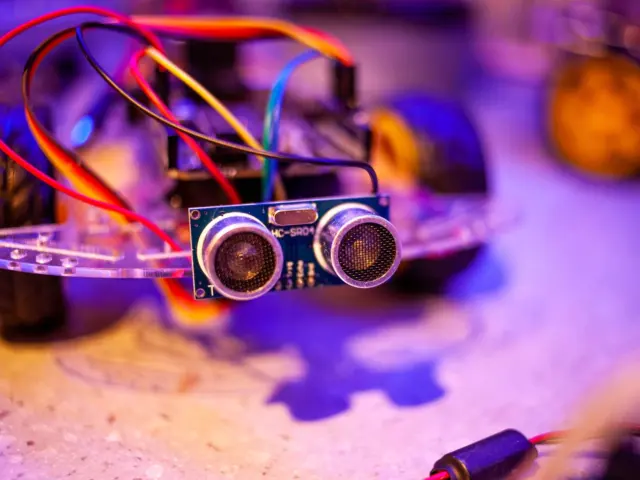
Indoor Robot Sensors Explained
The sensors used in indoor autonomous robots split into distance sensors, contact and drop sensors, and motion sensors, and most…
-
Visual SLAM for Indoor Robots
Quick answer: Visual SLAM for indoor robots uses camera images to estimate the robot’s position while building a map. It…
-
Indoor Autonomous Robots
Indoor autonomous robots navigate without GPS by combining sensors, odometry, a map and a planner. The first decision is whether…
-
The Kidnapped Robot Problem and Relocalization
Situation Effect on the robot Planning use Robot is carried elsewhere, displaced or switched off and moved It loses knowledge…
-
Robot Path Planning Algorithms
Planner Approach Property to know Planning use Dijkstra’s algorithm Grid or graph search, dated 1959 Finds the shortest path, given…