Browse
indoor robots
-
Model Predictive Path Integral Control for Robots
Effect of using MPPI What is supported Planning use Freedom in the cost function Non-quadratic and even discontinuous cost forms…
-
Obstacle Avoidance for Indoor Robots
Quick answer: how do autonomous robots avoid obstacles? They sense them, record them on a costmap, and let a local…
-
Lidar vs Camera Navigation for Indoor Robots
For lidar vs camera for robot navigation indoors, choose lidar when reliable distance measurement matters most, a camera when cost…
-
Visual SLAM for Indoor Robots
Quick answer: Visual SLAM for indoor robots uses camera images to estimate the robot’s position while building a map. It…
-
Robot Localization with Probabilistic Methods
Situation Effect on localization Planning use Known start pose, distinctive map features Uncertainty stays in one compact region, so a…
-
The Kidnapped Robot Problem and Relocalization
Situation Effect on the robot Planning use Robot is carried elsewhere, displaced or switched off and moved It loses knowledge…
-
How Indoor Robots Localize Without GPS
Position source What it gives the robot Main weakness Planning use Wheel odometry Change in position relative to the previous…
-
Visual SLAM Explained
What is visual SLAM? Visual SLAM is a method that lets a robot estimate its camera pose and build a…
-
Visual Inertial Odometry for Robots
A robot drives down a corridor and its camera sees only a blank wall. What is visual inertial odometry doing…
-
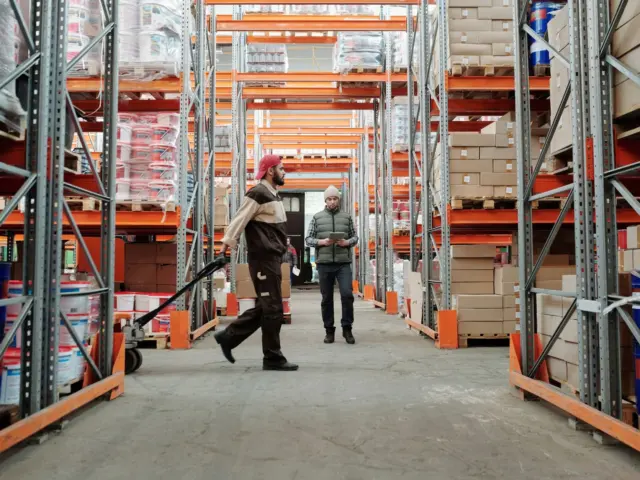
AMR vs AGV
Criterion AMR AGV Planning use Guidance SLAM-based navigation with sensors, 3D cameras and digital maps Floor markings, magnetic wires, QR…